The ACE_FK_701189 is a high-performance hardware solver designed for the real-time execution of Forward Kinematics (FK) and Jacobian Velocity Projections for 6-Degree-of-Freedom (6-DOF) robotic manipulators.
The core provides a dedicated, silicon-optimized path for complex matrix chain multiplications and trigonometric expansions. By offloading these tasks from the primary system processor, it delivers the deterministic, low-latency performance required for high-precision motion control, collision avoidance, and safety-critical monitoring.
Beyond raw computational throughput, the ACE701189 addresses a fundamental challenge in modern robotics: maintaining stable, high‑frequency control loops under strict timing constraints. Software‑based FK and Jacobian evaluation introduce jitter, variable execution time, and heavy CPU load, all of which degrade motion quality and complicate safety certification. By moving these operations into deterministic hardware, the ACE701189 ensures consistent cycle‑to‑cycle behavior, enabling tighter servo loops, predictable latency budgets, and reliable operation even in multi‑arm or safety‑critical environments.
DNA_PORT for secure node-locking and bitstream protection.The ACE701189 is designed for "Plug-and-Play" integration into modern SoC and FPGA architectures:
The ACE_FK architecture is modular and can be tailored by our engineering team to meet specific application requirements:
The ACE701189 core is engineered for high‑precision robotic manipulation where deterministic timing, safety‑critical behavior, and computational efficiency are non‑negotiable. By offloading all trigonometric, matrix‑chain, and Jacobian computations into dedicated silicon, the core eliminates the latency jitter and CPU load associated with software‑based kinematics.
The ACE701189 executes a multi-stage analytical routine to resolve the non-linear equations governing 6-axis robotic motion. The engine performs parallel execution of trigonometric expansions and matrix transformations, maintaining bit-perfect consistency with the Denavit-Hartenberg (DH) model across four computational phases:
By utilizing this core, the host system avoids per cycle: 12 simultaneous sine/cosine operations, chain multiplication of six $4 \times 4$ homogeneous transformation matrices, and calculation of the $6 \times 6$ Velocity Jacobian matrix.
Q2.30 fixed-point radians ($[-1.0, +1.0) \leftrightarrow [-\pi, +\pi)$).qn_d): Angular velocity in $\text{rad/s}$ (FP32).The core calculates the forearm orientation using sum-of-products to maintain pipeline integrity:
$$c_{23} = \cos(q_2)\cos(q_3) - \sin(q_2)\sin(q_3), \qquad s_{23} = \sin(q_2)\cos(q_3) + \cos(q_2)\sin(q_3)$$
The ACE Standard Core treats the tool offset as a 3D extension $(d_r, d_t, d_z)$ relative to the wrist center $(r_w, z_w)$, ensuring the tool tip is accurately tracked even when rotated by $q_4$:
$$r_w = A_2\cos(q_2) + A_3 c_{23} + D_4 s_{23}, \qquad z_w = D_1 + A_2\sin(q_2) + A_3 s_{23} - D_4 c_{23}$$
$$d_r = D_6\cos(q_4)\sin(q_5), \qquad d_t = D_6\sin(q_4)\sin(q_5), \qquad d_z = D_6\cos(q_5)$$
Final world-space coordinates account for the tangential shift ($d_t$) introduced by the spherical wrist:
$$r_{\text{total}} = r_w + c_{23}\,d_r + s_{23}\,d_z$$
$$P_X = \cos(q_1)\,r_{\text{total}} - \sin(q_1)\,d_t, \qquad P_Y = \sin(q_1)\,r_{\text{total}} + \cos(q_1)\,d_t, \qquad P_Z = z_w + s_{23}\,d_r - c_{23}\,d_z$$
Linear velocity is synthesized using planar differential components computed in parallel:
45–50).51–56).The final velocity vector in world space is the sum of joint rates ($\dot{q}_n$) multiplied by their respective Jacobian coefficients:
$$\begin{aligned} v_x &= -P_Y\,\dot{q}_1 + J_{v01}\,\dot{q}_2 + J_{v02}\,\dot{q}_3 + J_{v04}\,\dot{q}_4 + J_{v05}\,\dot{q}_5 \\ v_y &= \phantom{-}P_X\,\dot{q}_1 + J_{v11}\,\dot{q}_2 + J_{v12}\,\dot{q}_3 + J_{v14}\,\dot{q}_4 + J_{v15}\,\dot{q}_5 \\ v_z &= J_{v21}\,\dot{q}_2 + J_{v22}\,\dot{q}_3 + J_{v24}\,\dot{q}_4 + J_{v25}\,\dot{q}_5 \end{aligned}$$
Angular Velocity ($\omega_x, \omega_y, \omega_z$) — Standard Roll-Pitch-Roll Convention:
$$\begin{aligned} \omega_x &= \sin(q_1)\,\dot{q}_2 + \sin(q_1)\,\dot{q}_3 + \cos(q_1)c_{23}\,\dot{q}_4 + \big(\sin(q_1)\sin(q_4) - \cos(q_1)s_{23}\cos(q_4)\big)\,\dot{q}_5 \\ \omega_y &= -\cos(q_1)\,\dot{q}_2 - \cos(q_1)\,\dot{q}_3 + \sin(q_1)c_{23}\,\dot{q}_4 + \big(-\cos(q_1)\sin(q_4) - \sin(q_1)s_{23}\cos(q_4)\big)\,\dot{q}_5 \\ \omega_z &= \dot{q}_1 + s_{23}\,\dot{q}_4 + c_{23}\cos(q_4)\,\dot{q}_5 + \dot{q}_6 \end{aligned}$$
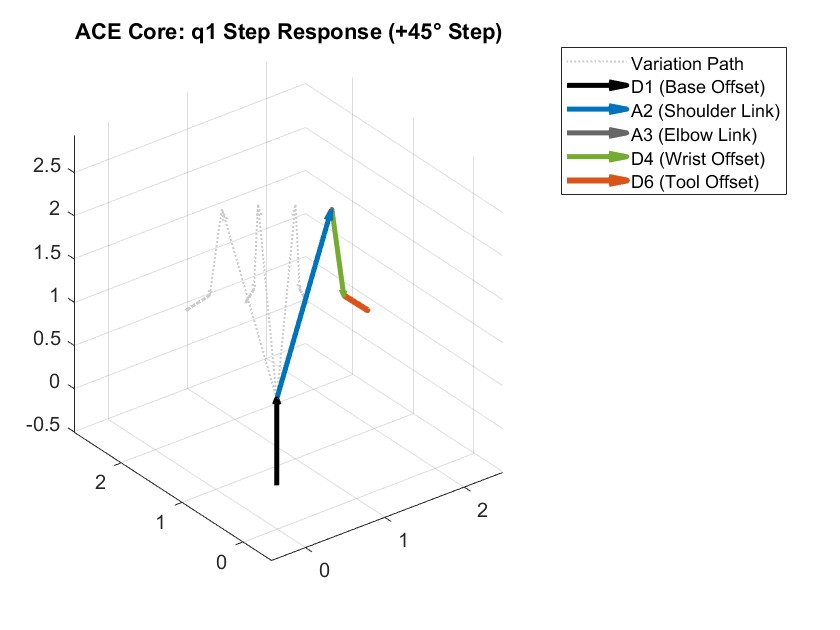
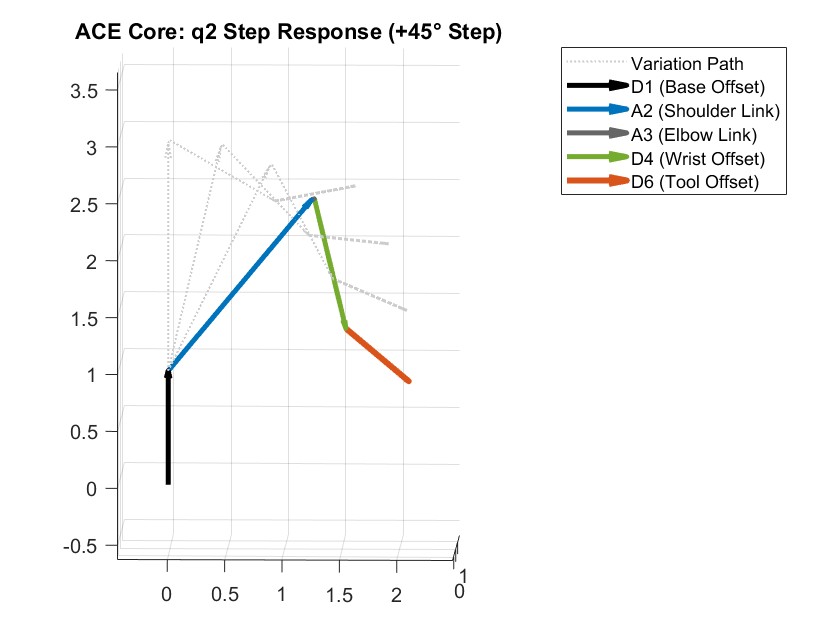
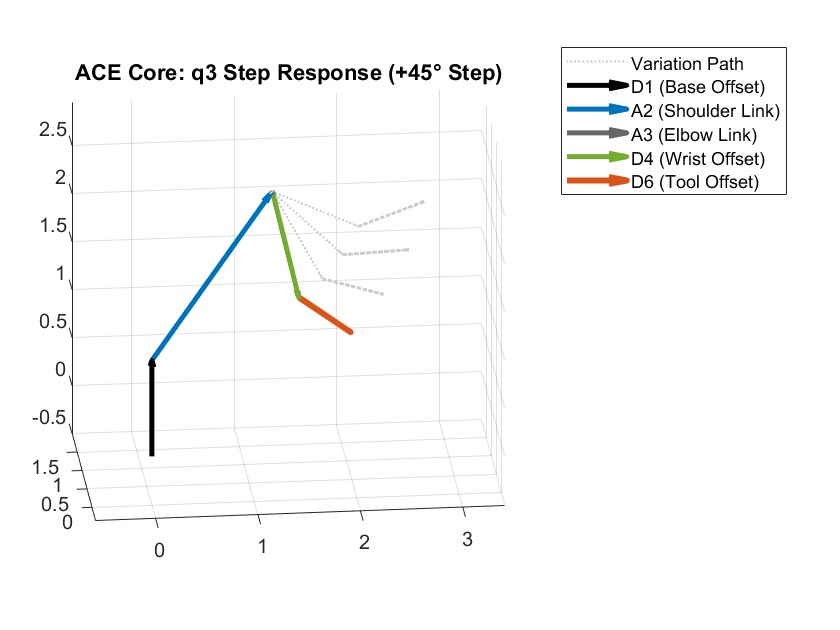
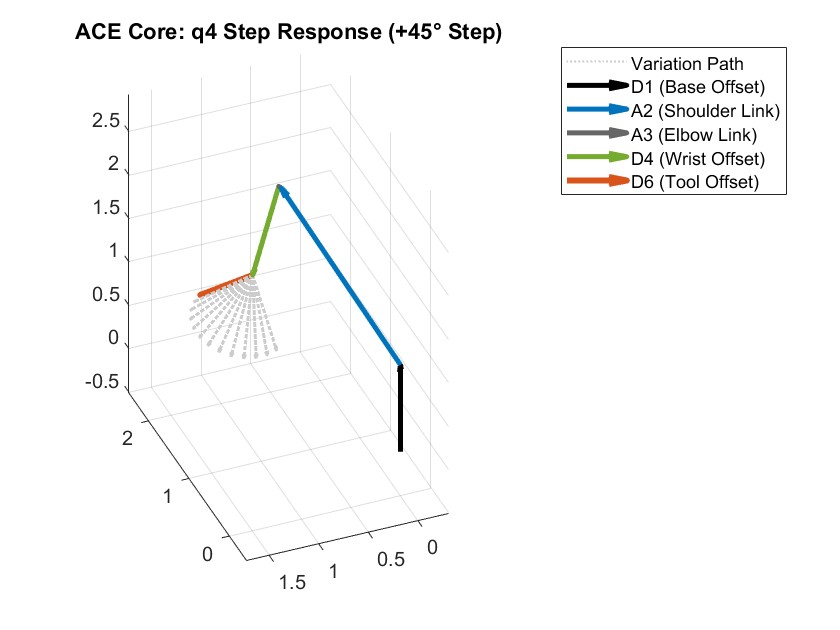
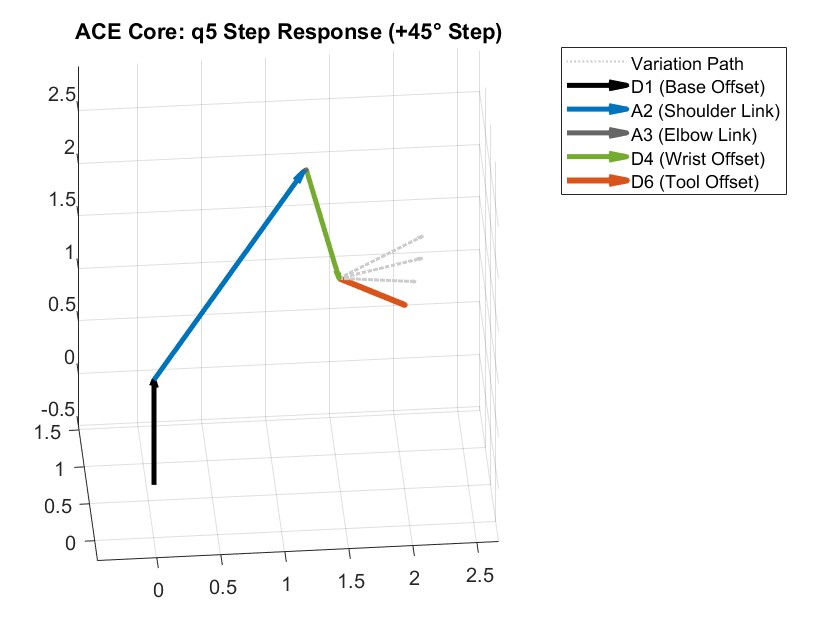
In this section, the variations of joint angles $q_1, q_2, q_3, q_4,$ and $q_5$ are illustrated by comparing the manipulator in a starting position and varying one angle at a time by $45^\circ$. For $q_6$, no image is generated since $q_6$ represents tool roll rotation around its own axis.
This section outlines the physical implementation results of the ACE_FK_701189 core. The core is optimized for the AMD/Xilinx 7-Series architecture while maintaining high portability for other FPGA fabrics.
Minimalist footprint on an AMD/Xilinx Artix-7 100T (xc7a100tcsg324-1) device:
| Resource Type | Used | Available | Utilization % |
|---|---|---|---|
| Slice LUTs | 4,008 | 63,400 | 6.32% |
| Slice Registers | 4,508 | 126,800 | 3.56% |
| DSP48E1 Slices | 6 | 240 | 2.50% |
| Block RAM (36Kb) | 3 | 135 | 2.22% |
The architecture is designed with high timing slack to ensure easy integration into congested user designs:
-1 speed grade silicon.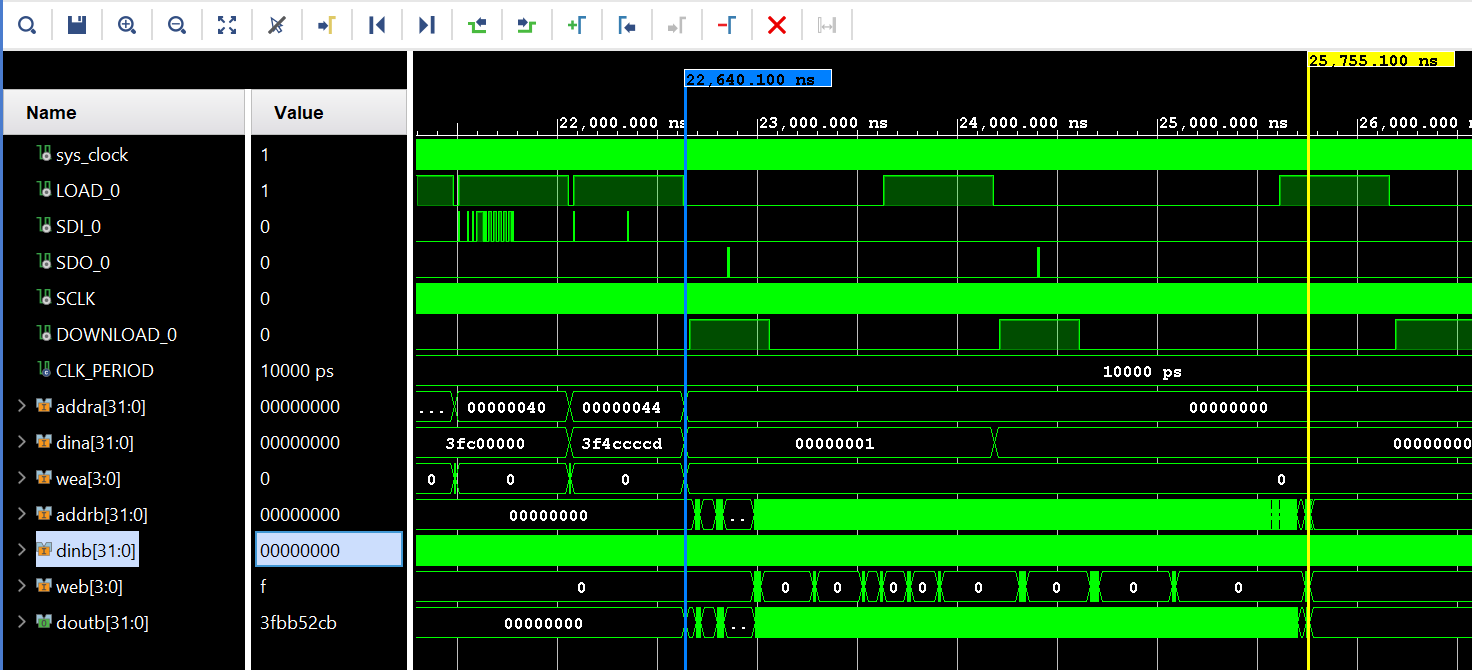
The ACE701189 core is packaged as an AMD IP core. Figure 2 shows the block configuration used in its verification project.
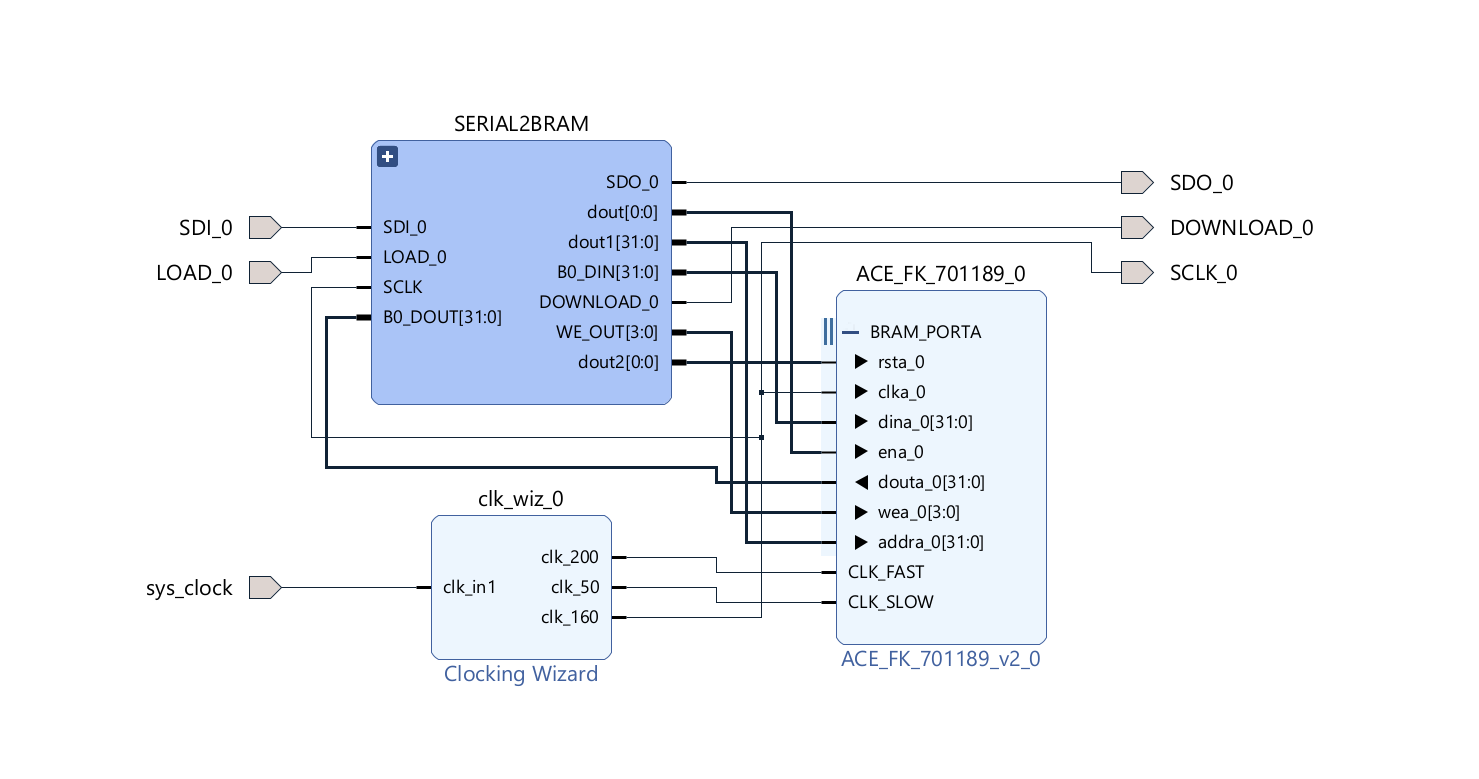
The core is managed entirely via read/write operations on a True Dual Port BRAM (32-bit width × 2048 locations) with port A available to the user and port B managed by the internal Math Engine. Only the first 64 locations (0–63) are used by the core, leaving the remainder free for user data.
| ADDR | VAR NAME | DIR | DESCRIPTION | FORMAT |
|---|---|---|---|---|
0 | START_CMD | IN-OUT | Set to 0x1 by the user to command execution; reset to 0x0 by the core when results are available in BRAM. | BINARY |
1 .. 6 | q1_fx .. q6_fx | INPUT | Joint 1 through 6 angular position inputs ($q_1 \dots q_6$). | FIXED POINT Q2.30 ($\pi = \text{01.000}\dots, -\pi = \text{11.000}\dots$) |
7 .. 12 | q1_d .. q6_d | INPUT | Joint 1 through 6 angular velocity inputs ($\dot{q}_1 \dots \dot{q}_6$). | FLOAT32 [rad/s] |
13 | A2 | INPUT | DH link length parameter $A_2$. | FLOAT32 [m] |
14 | A3 | INPUT | DH link length parameter $A_3$. | FLOAT32 [m] |
15 | D1 | INPUT | DH link offset parameter $D_1$. | FLOAT32 [m] |
16 | D4 | INPUT | DH link offset parameter $D_4$. | FLOAT32 [m] |
17 | D6 | INPUT | DH tool offset parameter $D_6$. | FLOAT32 [m] |
18 .. 20 | px, py, pz | OUTPUT | End-effector Cartesian world position outputs ($P_X, P_Y, P_Z$). | FLOAT32 [m] |
21 .. 23 | vx, vy, vz | OUTPUT | End-effector Cartesian linear velocity outputs ($v_x, v_y, v_z$). | FLOAT32 [m/s] |
24 .. 26 | wx, wy, wz | OUTPUT | End-effector Cartesian angular velocity outputs ($\omega_x, \omega_y, \omega_z$). | FLOAT32 [rad/s] |
27 .. 36 | s1, c1 .. s5, c5 | OUTPUT | Computed sine and cosine values for joints $q_1$ through $q_5$. | FLOAT32 |
37 .. 44 | N/A | INTERNAL | Reserved internal scratchpad locations. | N/A |
45 .. 56 | jv01 .. jv25 | OUTPUT | Linear Velocity Jacobian Matrix elements ($J_{v01}$ through $J_{v25}$). | FLOAT32 |
57 | DNA1 | OUTPUT | FPGA Silicon DNA (MSB). | BINARY |
58 | DNA2 | OUTPUT | FPGA Silicon DNA (LSB). | BINARY |
59 | USER_KEY1 | INPUT | User Security License Key (MSB). | BINARY |
60 | USER_KEY2 | INPUT | User Security License Key (LSB). | BINARY |
61 .. 63 | N/A | INTERNAL | Reserved internal scratchpad locations. | N/A |
In addition to the BRAM interface, the core exposes two clock slave interfaces:
CLK_SLOW: Access to the DNA reader primitive (max frequency $100\text{ MHz}$, suggested $50\text{ MHz}$).CLK_FAST: Internal computation engine clock (max frequency $200\text{ MHz}$).
At start up, the core automatically performs an initialization that lasts less than $5,000\text{ ns}$ (with CLK_SLOW @ $50\text{ MHz}$ and CLK_FAST @ $200\text{ MHz}$), populating the BRAM with the FPGA DNA (addresses 57 and 58). Once initialized, the user loads the BRAM inputs and sets START_CMD to 0x1; results are written after exactly 623 cycles and START_CMD resets to 0x0.
Note: if the USER_KEY is not correct, the core terminates in the specified timeframe, but produces unpredictable results.
The ACE_FK_701189 is delivered as a pre‑packaged Vivado IP core, ready for integration through the AMD/Xilinx IP Catalog as an encrypted, implementation‑ready DCP‑based IP bound to the FPGA’s silicon DNA identifier. Each licensed core includes:
USER_KEY file for license activationDNA_HEX,AUTHORIZATION_KEY
0011223344556677,C303E222F7D44C5B
ABCDE1234567890F,A2A3A3114194ED74
5566778899AABBCC,94C023F594AA6F63
DEADBEEF12345678,F40237F85DFB6F2A
00123456789ABCDE,E8ACBBDBFCF3ACB7
...............,.................BRAM_PORTA (addresses 57 and 58).USER_KEY from the CSV file.USER_KEY via BRAM_PORTA (addresses 59 and 60).Pricing is provided directly by ACE based on deployment volume, license type, optional customization requirements, and target FPGA family.
The ACE701189 has been tested with randomized inputs against a double-precision MATLAB golden model implementing the exact analytical equations:
function [pos, vel, J] = ace_solver_arm_standard(q, q_d, params)
   % ACE Standard 6-DOF Solver
   % Decoupled Spherical Wrist (Roll-Pitch-Roll convention)
   D1 = params.D1; A2 = params.A2; A3 = params.A3;
   D4 = params.D4; D6 = params.D6;

   % --- 1. TRIGONOMETRY ---
   s = sin(q); c = cos(q);
   s1=s(1); c1=c(1); s2=s(2); c2=c(2);
   s3=s(3); c3=c(3); s4=s(4); c4=c(4);
   s5=s(5); c5=c(5);

   % --- 2. FORWARD KINEMATICS ---
   c23 = c2*c3 - s2*s3;
   s23 = s2*c3 + c2*s3;

   % Wrist Center (The pivot point for q4, q5, q6)
   rw = A2*c2 + A3*c23 + D4*s23;
   zw = D1 + A2*s2 + A3*s23 - D4*c23;

   % Tool Offset Projection (Standard 6-DOF)
   dr = D6 * c4 * s5;  % Radial extension
   dt = D6 * s4 * s5;  % Tangential extension (The Decoupler)
   dz = D6 * c5;       % Vertical extension

   % Cartesian Position
   px = c1*(rw + c23*dr + s23*dz) - s1*dt;
   py = s1*(rw + c23*dr + s23*dz) + c1*dt;
   pz = zw + s23*dr - c23*dz;
   pos = [px; py; pz];

   % --- 3. ANALYTICAL JACOBIAN (Geometric) ---
   Jv1 = [-py; px; 0];
   Jv2 = [c1*( -A2*s2 - A3*s23 + D4*c23 + (-s23*dr + c23*dz) );
          s1*( -A2*s2 - A3*s23 + D4*c23 + (-s23*dr + c23*dz) );
               ( A2*c2 + A3*c23 + D4*s23 + ( c23*dr + s23*dz) )];
   Jv3 = [c1*( -A3*s23 + D4*c23 + (-s23*dr + c23*dz) );
          s1*( -A3*s23 + D4*c23 + (-s23*dr + c23*dz) );
               ( A3*c23 + D4*s23 + ( c23*dr + s23*dz) )];
   Jv4 = [ -c1*c23*(D6*s4*s5) - s1*(D6*c4*s5);
           -s1*c23*(D6*s4*s5) + c1*(D6*c4*s5);
           -s23*(D6*s4*s5) ];
   Jv5 = [ c1*(c23*D6*c4*c5 - s23*D6*s5) - s1*(D6*s4*c5);
           s1*(c23*D6*c4*c5 - s23*D6*s5) + c1*(D6*s4*c5);
              (s23*D6*c4*c5 + c23*D6*s5) ];

   % --- 4. ASSEMBLE JACOBIAN ---
   J = [ Jv1, Jv2, Jv3, Jv4, Jv5, [0;0;0] ];
   Jw = [ 0,  s1,  s1,  c1*c23,  s1*s4 - c1*s23*c4,  0;
          0, -c1, -c1,  s1*c23, -c1*s4 - s1*s23*c4,  0;
          1,   0,   0,  s23,     c23*c4,             1 ];
   J = [J; Jw];
   vel = J * q_d;
end
Verification trace results showing absolute errors below $10^{-5}$ across all test stages:
==========================================================================
--- STAGE 1 FULL TRACE & VERIFICATION ---
==========================================================================
ROBOT PARAMS (m): A2=1.00, A3=0.60, D1=1.50, D4=1.50, D6=0.80
INPUT ANGLES (rad): [1.9775, 2.5497, -2.3437, 2.5973, 0.8316, -2.5287]
INPUT RATES (rad/s): [-0.4430, 0.0938, 0.9150, 0.9298, -0.6848, 0.9412]
--------------------------------------------------------------------------
Var      | MATLAB (Gold)  | CORE (BRAM)    | Abs Error    | Addr
--------------------------------------------------------------------------
px       |      -0.154319 |      -0.154318 |   1.0802e-06    | 18
py       |      -0.415629 |      -0.415628 |   1.2510e-06    | 19
pz       |       0.081383 |       0.081382 |   1.4593e-06    | 20
vx       |      -0.389489 |      -0.389492 |   3.1828e-06    | 21
vy       |       2.217214 |       2.217215 |   1.2438e-07    | 22
vz       |       0.045890 |       0.045891 |   1.1873e-06    | 23
wx       |       0.288231 |       0.288230 |   9.0113e-07    | 24
wy       |       0.984640 |       0.984641 |   6.5121e-07    | 25
wz       |       1.261768 |       1.261770 |   1.1548e-06    | 26
------------------- JACOBIAN COLUMN PRODUCERS ----------------------------
Jv2_x    |      -0.561140 |      -0.561141 |   1.4012e-06    | 45
Jv2_y    |       1.302918 |       1.302918 |   3.6642e-08    | 46
Jv2_z    |      -0.320690 |      -0.320689 |   7.9042e-07    | 47
Jv3_x    |      -0.781843 |      -0.781845 |   1.9298e-06    | 48
Jv3_y    |       1.815374 |       1.815374 |   1.4038e-07    | 49
Jv3_z    |       0.509178 |       0.509179 |   9.6607e-07    | 50
Jv4_x    |       0.583081 |       0.583080 |   9.1045e-07    | 51
Jv4_y    |      -0.075157 |      -0.075156 |   9.9995e-07    | 52
Jv4_z    |      -0.062606 |      -0.062606 |   1.1760e-07    | 53
Jv5_x    |      -0.029955 |      -0.029953 |   1.4333e-06    | 54
Jv5_y    |      -0.635936 |      -0.635936 |   1.7574e-07    | 55
Jv5_z    |       0.484446 |       0.484446 |   1.6558e-07    | 56
==========================================================================
--- STAGE 2 FULL TRACE & VERIFICATION ---
==========================================================================
ROBOT PARAMS (m): A2=1.00, A3=0.60, D1=1.50, D4=1.50, D6=0.80
INPUT ANGLES (rad): [2.8725, -0.0919, 1.8867, -2.2501, -0.4916, 2.6121]
INPUT RATES (rad/s): [0.5844, 0.9190, 0.3115, -0.9286, 0.6983, 0.8680]
--------------------------------------------------------------------------
Var      | MATLAB (Gold)  | CORE (BRAM)    | Abs Error    | Addr
--------------------------------------------------------------------------
px       |      -2.931501 |      -2.931498 |   3.4421e-06    | 18
py       |       0.503800 |       0.503798 |   2.1994e-06    | 19
pz       |       2.714490 |       2.714491 |   3.0076e-07    | 20
vx       |       1.078501 |       1.078504 |   2.6477e-06    | 21
vy       |      -1.465925 |      -1.465922 |   2.8022e-06    | 22
vz       |       3.354848 |       3.354843 |   4.7236e-06    | 23
wx       |      -0.428467 |      -0.428468 |   6.2317e-07    | 24
wy       |       0.831052 |       0.831052 |   4.9353e-07    | 25
wz       |       0.644489 |       0.644491 |   1.7867e-06    | 26
------------------- JACOBIAN COLUMN PRODUCERS ----------------------------
Jv2_x    |       1.170772 |       1.170773 |   8.9986e-07    | 45
Jv2_y    |      -0.322922 |      -0.322922 |   2.9231e-07    | 46
Jv2_z    |       2.959932 |       2.959927 |   5.3990e-06    | 47
Jv3_x    |       1.259228 |       1.259229 |   1.4494e-06    | 48
Jv3_y    |      -0.347320 |      -0.347320 |   4.2418e-07    | 49
Jv3_z    |       1.964151 |       1.964146 |   4.7930e-06    | 50
Jv4_x    |      -0.126001 |      -0.126002 |   6.7817e-07    | 51
Jv4_y    |      -0.211345 |      -0.211345 |   5.0820e-07    | 52
Jv4_z    |      -0.286453 |      -0.286453 |   6.8236e-07    | 53
Jv5_x    |      -0.303928 |      -0.303929 |   5.2464e-07    | 54
Jv5_y    |       0.653026 |       0.653027 |   7.3968e-07    | 55
Jv5_z    |      -0.348115 |      -0.348114 |   1.5802e-06    | 56
==========================================================================
--- STAGE 3 FULL TRACE & VERIFICATION ---
==========================================================================
ROBOT PARAMS (m): A2=1.00, A3=0.60, D1=1.50, D4=1.50, D6=0.80
INPUT ANGLES (rad): [1.1230, 1.6194, 1.5276, -0.6772, 0.9769, -2.0660]
INPUT RATES (rad/s): [0.4121, -0.9363, -0.4462, -0.9077, -0.8057, 0.6469]
--------------------------------------------------------------------------
Var      | MATLAB (Gold)  | CORE (BRAM)    | Abs Error    | Addr
--------------------------------------------------------------------------
px       |      -0.134681 |      -0.134678 |   3.2123e-06    | 18
py       |      -1.239925 |      -1.239919 |   5.7437e-06    | 19
pz       |       4.440344 |       4.440342 |   1.7339e-06    | 20
vx       |       2.580724 |       2.580716 |   8.6294e-06    | 21
vy       |       3.692495 |       3.692491 |   3.7572e-06    | 22
vz       |       2.141928 |       2.141919 |   8.1651e-06    | 23
wx       |      -0.399629 |      -0.399628 |   2.9566e-07    | 24
wy       |       1.195035 |       1.195033 |   2.2869e-06    | 25
wz       |       1.691931 |       1.691929 |   2.2504e-06    | 26
------------------- JACOBIAN COLUMN PRODUCERS ----------------------------
Jv2_x    |      -1.273041 |      -1.273038 |   3.4778e-06    | 45
Jv2_y    |      -2.650469 |      -2.650465 |   3.8783e-06    | 46
Jv2_z    |      -1.175998 |      -1.175993 |   5.0476e-06    | 47
Jv3_x    |      -0.840597 |      -0.840594 |   2.4531e-06    | 48
Jv3_y    |      -1.750120 |      -1.750117 |   2.9831e-06    | 49
Jv3_z    |      -1.127384 |      -1.127380 |   4.1357e-06    | 50
Jv4_x    |      -0.645642 |      -0.645640 |   1.7686e-06    | 51
Jv4_y    |      -0.150751 |      -0.150751 |   3.8472e-07    | 52
Jv4_z    |      -0.002278 |      -0.002277 |   3.9680e-07    | 53
Jv5_x    |       0.103370 |       0.103370 |   4.4632e-07    | 54
Jv5_y    |      -0.432670 |      -0.432669 |   8.1506e-07    | 55
Jv5_z    |      -0.664915 |      -0.664913 |   1.6216e-06    | 56
==========================================================================
--- STAGE 4 FULL TRACE & VERIFICATION ---
==========================================================================
ROBOT PARAMS (m): A2=1.00, A3=0.60, D1=1.50, D4=1.50, D6=0.80
INPUT ANGLES (rad): [1.2241, -1.1492, 2.8288, -2.9252, -0.3849, -0.7442]
INPUT RATES (rad/s): [0.5310, 0.5904, -0.6263, -0.0205, -0.1088, 0.2926]
--------------------------------------------------------------------------
Var      | MATLAB (Gold)  | CORE (BRAM)    | Abs Error    | Addr
--------------------------------------------------------------------------
px       |       0.802438 |       0.802437 |   1.5539e-06    | 18
py       |       2.411197 |       2.411197 |   6.8197e-07    | 19
pz       |       1.719098 |       1.719095 |   2.7401e-06    | 20
vx       |      -1.108264 |      -1.108265 |   6.0527e-07    | 21
vy       |       0.936037 |       0.936037 |   3.9587e-07    | 22
vz       |       0.241296 |       0.241295 |   9.1557e-07    | 23
wx       |      -0.046885 |      -0.046885 |   8.3973e-08    | 24
wy       |      -0.093042 |      -0.093042 |   1.6542e-07    | 25
wz       |       0.791764 |       0.791765 |   1.4516e-07    | 26
------------------- JACOBIAN COLUMN PRODUCERS ----------------------------
Jv2_x    |      -0.074439 |      -0.074438 |   1.0828e-06    | 45
Jv2_y    |      -0.206065 |      -0.206062 |   2.6396e-06    | 46
Jv2_z    |       2.540397 |       2.540397 |   5.2009e-07    | 47
Jv3_x    |      -0.384440 |      -0.384438 |   1.4146e-06    | 48
Jv3_y    |      -1.064225 |      -1.064223 |   2.0200e-06    | 49
Jv3_z    |       2.131177 |       2.131179 |   2.1599e-06    | 50
Jv4_x    |      -0.273521 |      -0.273521 |   2.5817e-08    | 51
Jv4_y    |       0.106256 |       0.106255 |   2.3750e-07    | 52
Jv4_z    |      -0.064119 |      -0.064119 |   3.4029e-07    | 53
Jv5_x    |       0.277925 |       0.277925 |   1.8821e-07    | 54
Jv5_y    |       0.300703 |       0.300702 |   9.9778e-07    | 55
Jv5_z    |      -0.687267 |      -0.687267 |   5.1558e-07    | 56
==========================================================================
--- STAGE 5 FULL TRACE & VERIFICATION ---
==========================================================================
ROBOT PARAMS (m): A2=1.00, A3=0.60, D1=1.50, D4=1.50, D6=0.80
INPUT ANGLES (rad): [1.3155, 1.6002, -1.4073, 1.1291, 0.9745, -2.1199]
INPUT RATES (rad/s): [-0.7620, -0.0033, 0.9195, -0.3192, 0.1705, -0.5524]
--------------------------------------------------------------------------
Var      | MATLAB (Gold)  | CORE (BRAM)    | Abs Error    | Addr
--------------------------------------------------------------------------
px       |      -0.273188 |      -0.273185 |   3.1299e-06    | 18
py       |       1.322819 |       1.322818 |   4.8002e-07    | 19
pz       |       0.755814 |       0.755814 |   5.3647e-07    | 20
vx       |       1.482697 |       1.482699 |   1.6948e-06    | 21
vy       |       1.943440 |       1.943434 |   5.8817e-06    | 22
vz       |       1.290261 |       1.290263 |   1.8349e-06    | 23
wx       |       0.953030 |       0.953028 |   1.8926e-06    | 24
wy       |      -0.587003 |      -0.587005 |   1.3054e-06    | 25
wz       |      -1.304054 |      -1.304055 |   3.6034e-07    | 26
------------------- JACOBIAN COLUMN PRODUCERS ----------------------------
Jv2_x    |       0.187947 |       0.187948 |   9.7380e-07    | 45
Jv2_y    |       0.720062 |       0.720060 |   1.4385e-06    | 46
Jv2_z    |       1.210942 |       1.210942 |   1.5520e-07    | 47
Jv3_x    |       0.440391 |       0.440393 |   2.3604e-06    | 48
Jv3_y    |       1.687225 |       1.687222 |   3.0161e-06    | 49
Jv3_z    |       1.240385 |       1.240387 |   1.8140e-06    | 50
Jv4_x    |      -0.422113 |      -0.422113 |   1.7273e-07    | 51
Jv4_y    |      -0.496807 |      -0.496805 |   1.5223e-06    | 52
Jv4_z    |      -0.114759 |      -0.114760 |   5.8192e-07    | 53
Jv5_x    |      -0.377436 |      -0.377436 |   4.2210e-07    | 54
Jv5_y    |       0.162116 |       0.162116 |   3.9676e-07    | 55
Jv5_z | 0.686484 | 0.686484 | 2.7423e-07 | 56Data Privacy note: By contacting us via email, you agree that we will use your provided contact details and mathematical specifications solely to evaluate project feasibility during our early-access phase. We do not sell or share your personal information with third parties. We may use standard web analytics tools to monitor basic, aggregated website traffic to improve our site performance.